Real-time obstacle detection & avoidance
Fuses camera, LiDAR, and depth data to detect static and moving obstacles and re-route around them in real time, even in cluttered or dynamic environments.
NAVIGATION KIT
A drop-in navigation stack that gives any ground vehicle - wheeled, tracked, or legged - the ability to sense, avoid, and move through real-world terrain without a driver, built on our production ROS1/ROS2 stack.
Fuses camera, LiDAR, and depth data to detect static and moving obstacles and re-route around them in real time, even in cluttered or dynamic environments.
Terrain-aware path planning that adapts to unpaved, uneven, and unstructured ground - mud, gravel, slopes, dense vegetation - without relying on pre-mapped roads.
The platform tracks and follows a designated person or vehicle at a safe, configurable distance, using vision-based re-identification to keep following the right target through occlusion.
Plan a route as a sequence of GPS or map-relative waypoints; the platform handles path planning, obstacle avoidance, and arrival logic autonomously.
The platform keeps pace with a person walking ahead of it, holding a safe following distance over uneven, off-road terrain.
The Navigation Kit runs on your existing robot base and is sensor-agnostic - camera, LiDAR, radar, or a fused rig. It's available as a standalone software stack for your platform, or bundled with a sensor kit and edge-compute hardware for a turnkey deployment.
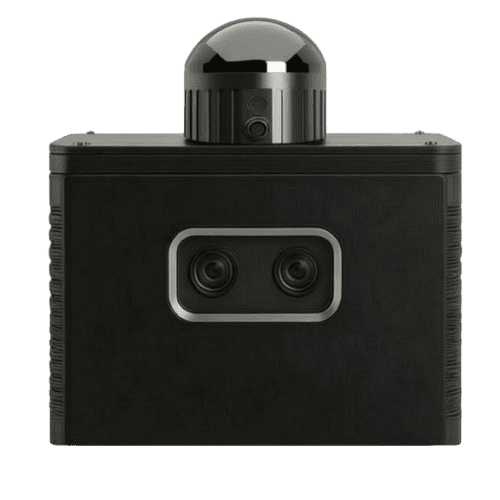
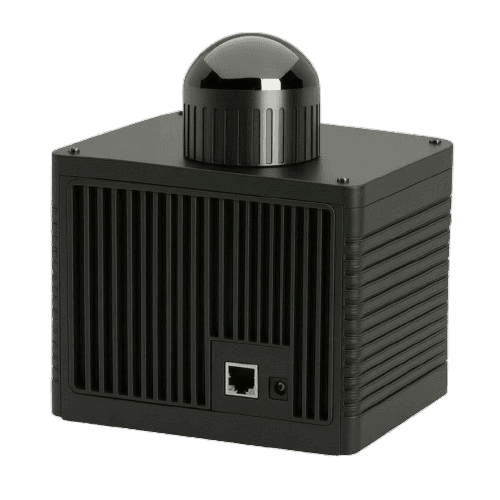
A ruggedized LiDAR-and-camera unit that mounts to your platform, fusing point-cloud and visual data for obstacle detection and autonomous navigation.